Posts
Miscellaneous musings, newest first.
2026
-
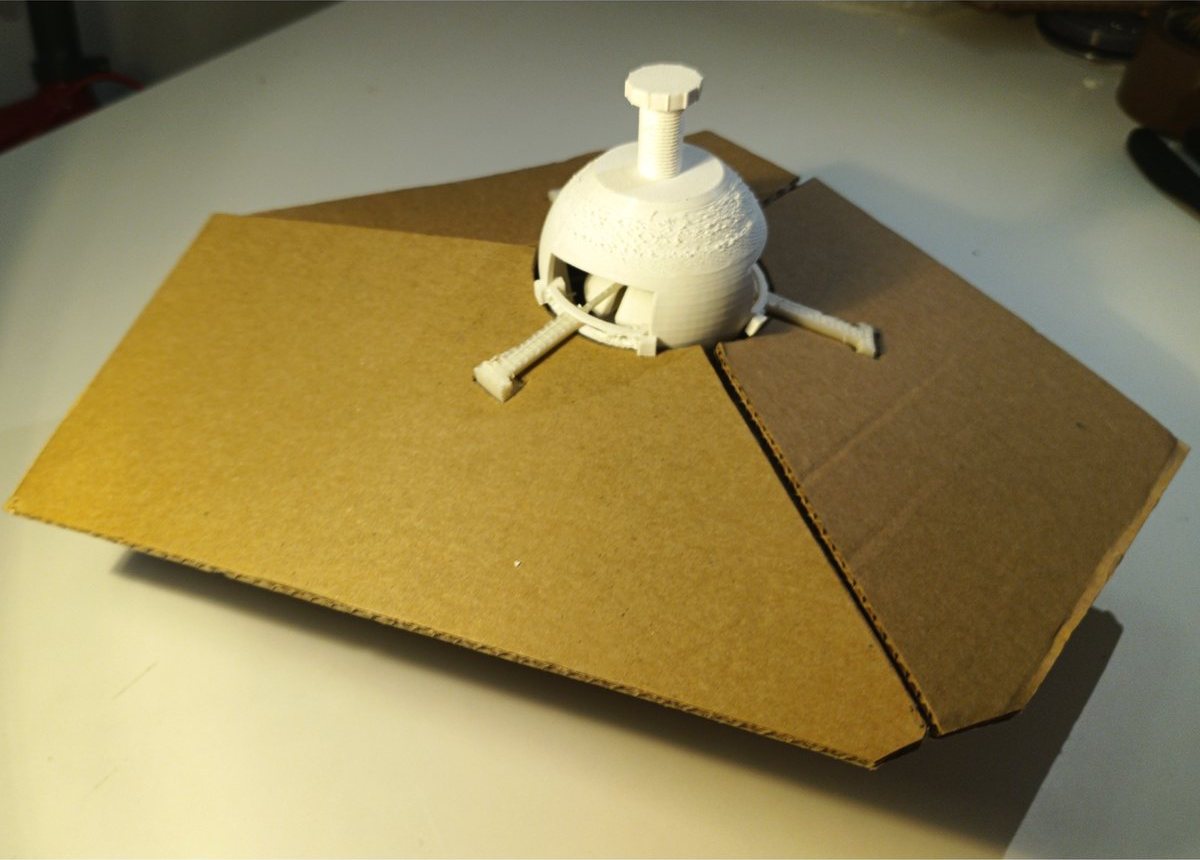
One kit of flat panels, many curved shells: a reconfigurable 3D-printed joint
How a finite kit of ten flat panel types and one adjustable 3D-printed vertex joint can build doubly curved shells, from our IASS 2026 paper.
-
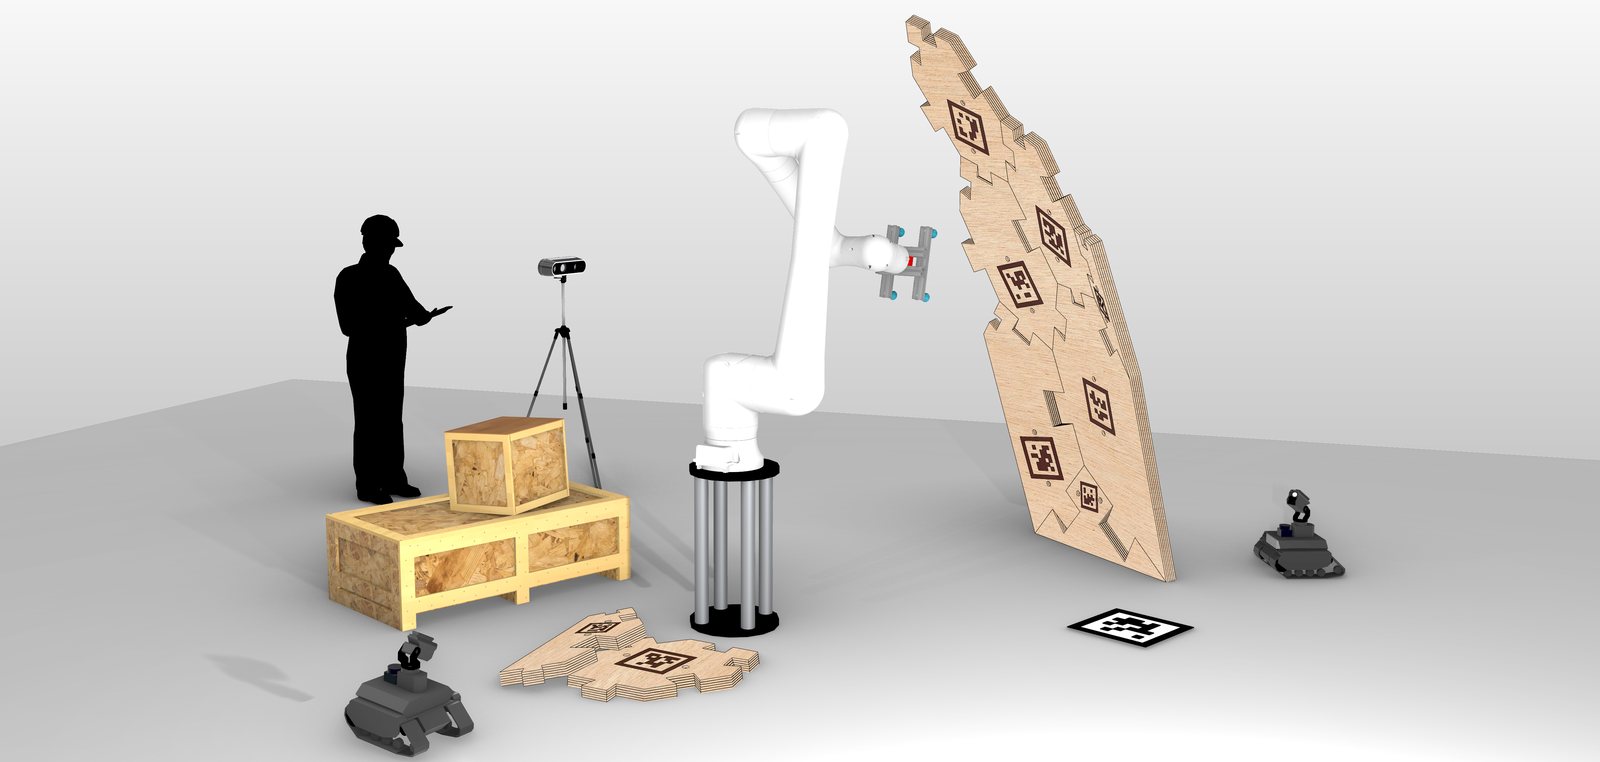
Heterogeneous robot teams for cluttered construction sites
A fixed robot arm and a mobile rover share the job of assembly on a messy site: the rover scouts and tracks panels, the arm places them, and a person supervises by voice.
-
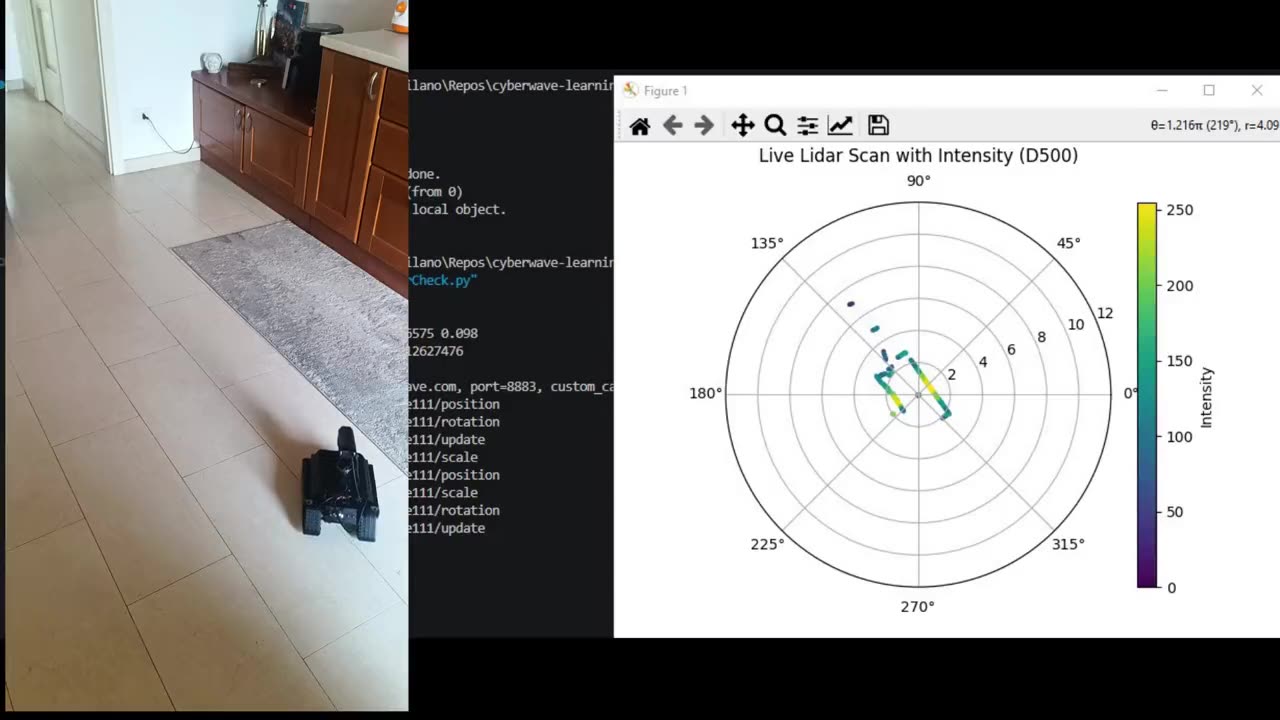
Cyberwave and the joyful plumbing of a cloud-connected lidar
Integrating a Waveshare D500 lidar with a UGV Beast through Cyberwave, ROS 2, and a digital twin workflow.
2025
-
New Arch // Struct Lab website
I built the new Arch // Struct Lab (AS Lab) website at the Politecnico di Milano to showcase the lab's research projects and publications in one place.
-
Kinetic Harlequin: an interactive kinetic sculpture simulating nature through discrete mechanisms
A kinetic sculpture driven by servomotors, constructed for Milan Design Week 2025.


2024
-
Network visualisation
An interactive network graph of robotics topics, built with Retina.
-
Snake in the terminal with Python and curses
A late-night terminal Snake game in Python using UniCurses, with super foods and teleporting. Full code included.
-
W.AMCA 24 Gallery
Images from the Workshop on Additive Manufacturing and Construction Automation 2024
-
Light painting
Light painting with a Fanuc CR10ia/L and Python
-
Whispers from a summer nest - Milano 2024
An international summer workshop in Milan on building with reused materials.




2023
-
Controlling the KUKA iiwa from Grasshopper and ROS: Room g02a guide
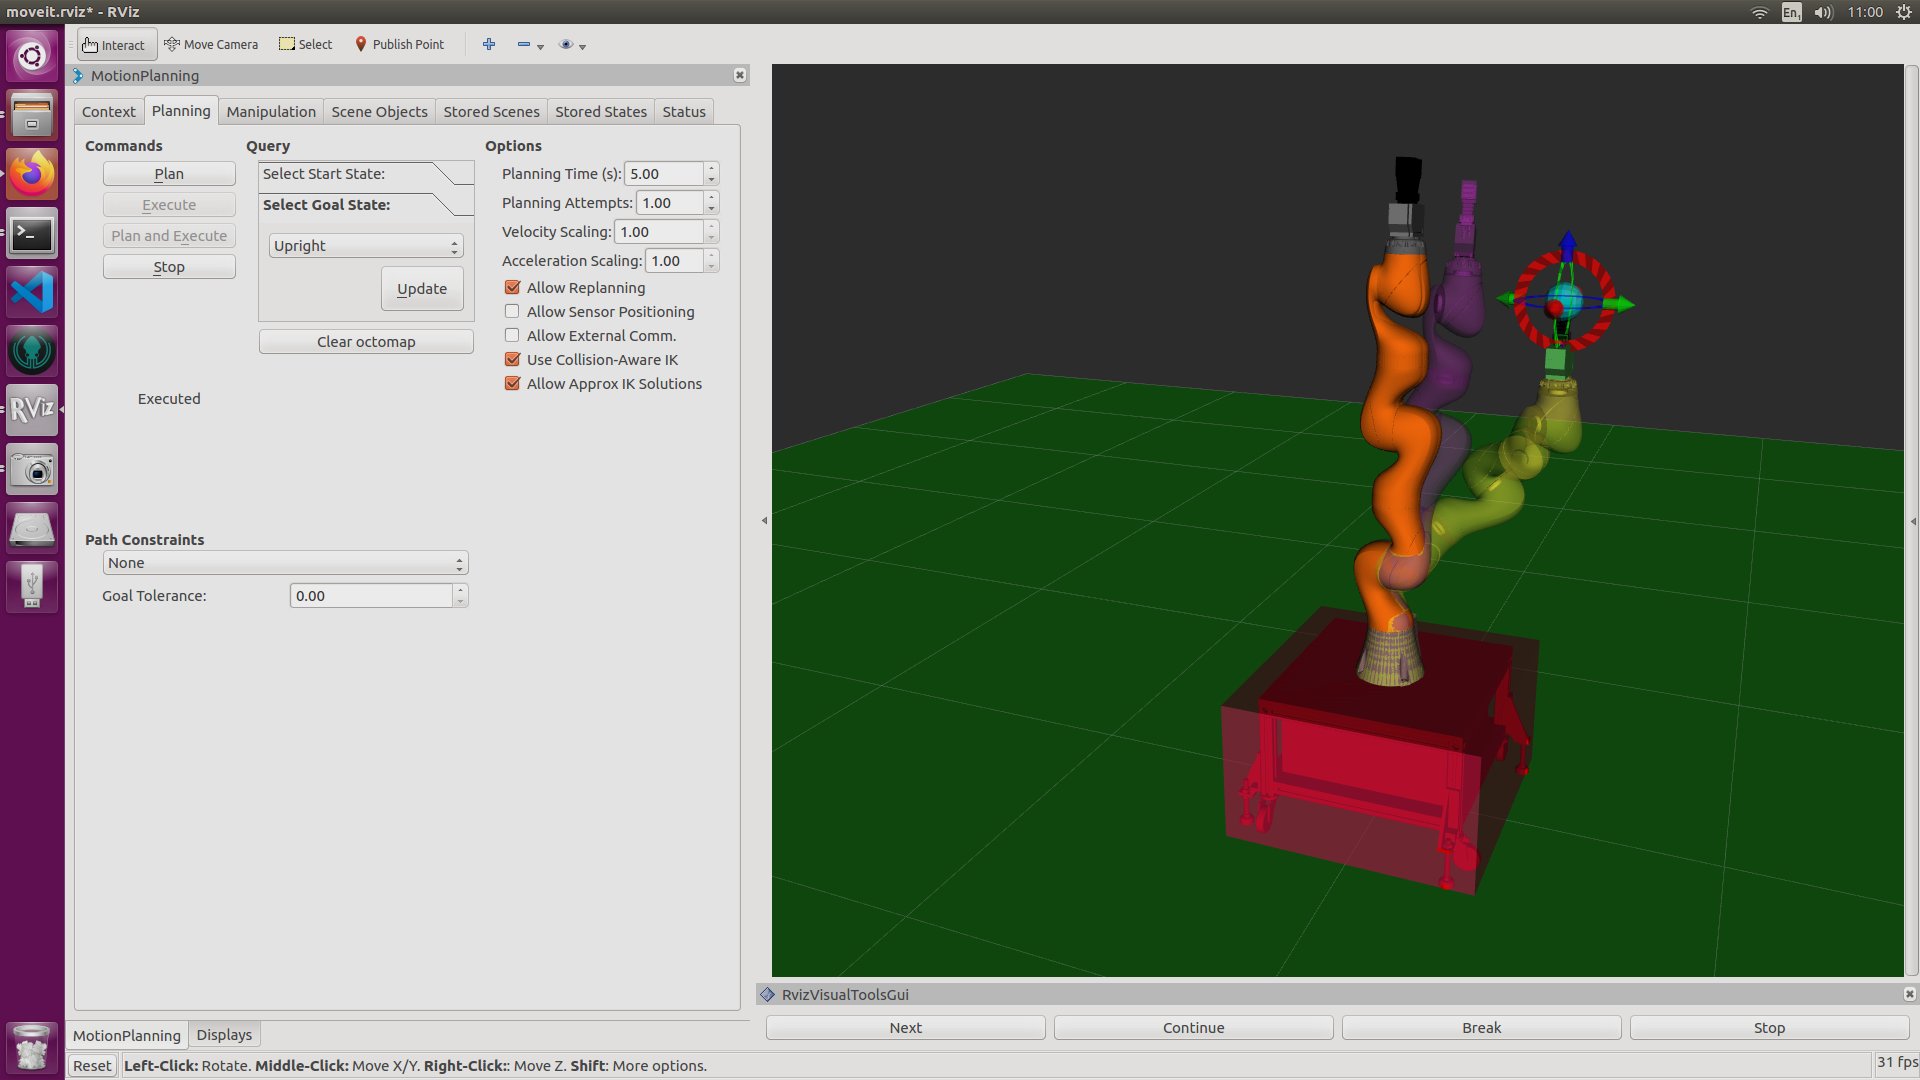
Step-by-step setup for driving the KUKA LBR iiwa in Leeds room g02a from Rhino/Grasshopper through ROS and COMPAS: installs, simulation, real control and the gripper.
2022
-
Be Curious 2022: AprilTag control of a PincherX robot arm
Families at the University of Leeds' Be Curious day steered a PincherX robot arm with an AprilTag paddle and a webcam, through a sweet-powered pick-and-place task.
-
Leeds International Summer School 2022 - Digital design and fabrication
Leeds International Summer School Course

2021
-
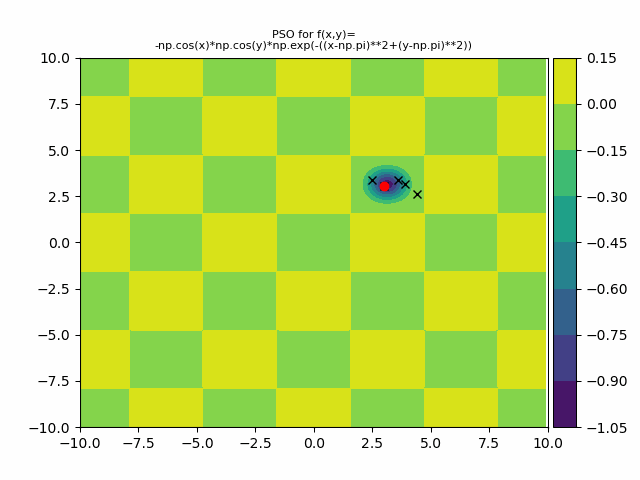
Playing with Particle Swarm Optimisation
Quick study of PSO for a few test functions
-
Creating a robot reachability map
Scoring a manipulator's workspace by testing how many orientations inverse kinematics can reach at each point of a voxel grid, following Zacharias et al. (2007).

2020
-
Grasshopper to ROS: sending Rhino geometry to a robot arm
Sending generatively designed geometry from Rhino and Grasshopper over ROS2, following COMPAS FAB, so a simulated robot arm can plan with MoveIt around it.
-
ROS2 and MoveIt2 demo: motion planning for a Denso VS068 arm
A first ROS2 and MoveIt2 demo: a Denso VS068 manipulator exported from SolidWorks to URDF and motion-planned in RViz, with video and setup notes.
-
Rhino/Iris Test
Three.js model posting test
-
You say tomato, I say To-Mammon
Lockdown: Creative inspiration or gradual insanity?
-
Starting off
This is my first blog post, as a test